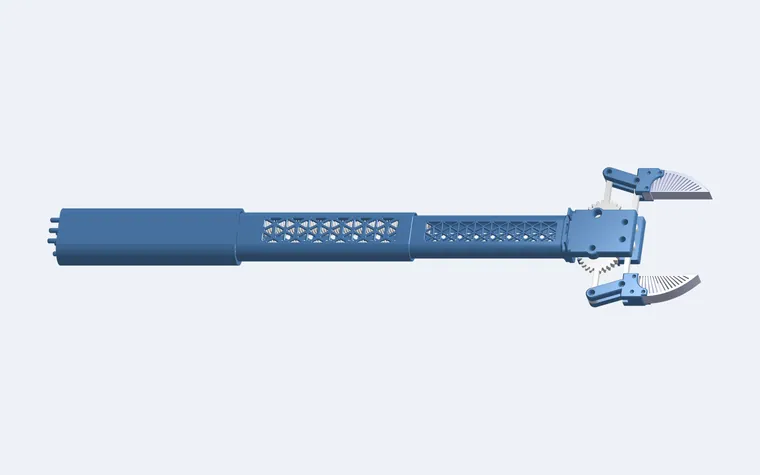
A grabber for seniors that extends on its own, so picking something up never means bending, stretching or squeezing. Our four-person team built it for Project Invent with Mozaic Senior Life, after hearing that residents were losing grip strength to arthritis.
I owned the mechanical design and fabrication: the CAD, the printing and the telescoping mechanism. Six months and three versions later, Reach won the Product Pivot award at Project Invent, and version 0.3 is being refined to go to residents.
- Onshape CAD
- 3D printing (PETG)
- N20 gear motor
- Joystick + motor controller
- Lead-screw mechanism
How it works
- An N20 gear motor spins a lead screw. The connector riding on it can't rotate, so the thread drives it upward and the next stage climbs out of the one below
- Twin lead screws per connector stop it from spinning and leave a channel down the middle for wires
- 3 mm steel balls in a printed race let lead screw B spin freely without pulling out
- A four-bar linkage closes Fin Ray fingers in a straight line, run from a joystick through a motor controller on a 6 V LiPo battery
Proof of concept
A drill stands in for the motor. After tolerance tests set a 1.5 mm thread offset, the printed lead screws extend exactly as planned.
WorkedRetired for safety
The connector's anti-rotation wings poked through the shell and made pinch points for fingers, so I scrapped it.
RetiredTwo screws, not one
Twin lead screws removed the wings, steel bearing balls fixed the friction, and the claw joined three stages in one model.
Product Pivot award